Как правильно установить драйверы и программы Acer на ноутбук Acer Aspire 3 a315-22?
Имеется новый ноут Acer Aspire A315-22 без предустановленной ОС. В комплекте ключ Win10 для сборщиков систем. Проц AMD.
Установил Windows, скачал драйверы с оф. сайта https://www.acer.com/ac/ru/RU/content/support-prod. . Установил Acer Care Center и Quick Access Application.
Но в итоге так и не работает тачпад и кнопки с комбинацией Fn +» «.
На сайте Acer прочитал: Перед установкой драйвера сенсорной панели (тачпада) сначала установите устройства Serial I/O.
Что значит «установите устройства Serial I/O», как их устанавливать? По какой причине могут не работать кнопки с комбинацией Fn ?
Intel Serial IO Driver что это за драйвер?
 Всем приветандр Поговорим сегодня о такой штуке как Intel Serial IO Driver. И сразу есть хорошая новость, я узнал что это такое! Это драйвер от компании Intel для последовательного ввода-вывода. Честно я не знаю за что именно драйвер отвечает, но что-то мне подсказывает, что сам драйвер важный. Вот нашел инфу на одном форуме, что этот драйвер отвечает за тачскрин и тачпад, это конечно имеется ввиду если у вас ноутбук или планшет.
Минутку внимания, так бы сказать памятка. Никогда не удаляйте ничего, что в имени своем имеет слово driver, ибо после этого могут быть проблемы, может какое-то устройство перестать работать. Или могут пропасть некоторые функции, например дополнительные возможности мышки, ну или еще что-то..
Набрел на форум фанатов Acer, на этом форуме узнал, что есть такая ошибка что типа не определяется устройства типа Intel Serial IO GPIO controller и Intel Serial I2C ES controller. И вот чтобы эту ошибку исправить, то нужно скачать Intel Serial IO Driver и потом установить этот драйвер. Скачать как я понял можно с официального сайта.
Короче ребята что-то инфы вообще нет про Intel Serial IO Driver. Удалять или трогать это не советую вообще. А вот что советую, так это установить программу от Intel для обновления драйверов, скачайте ее с официального сайта, она проверит комп и если нужно то поставит сама драйвера. Вот как эта программа выглядит:

По-английски эта программа называется как Intel® Driver Update Utility.
В общем исходя из всего что я узнал в интернете, то мне кажется что Intel(R) Serial IO Driver относится к тачпаду, к операциям ввода-вывода.. В любом случае удалять не нужно.. На этой ноте закончим, ибо инфы больше нет, удачи вам ребята
Устройства serial i o что это
serial_putc function is waiting, no useful work is being done.
[9.3] We can illustrate the problem with a program for printing the first 500 primes.
The program uses printf to print its results, a wrapper around serial_putc that looks like the standard C function for formatted output. I’ve included calls to functions start_timer and stop_timer that turn on and off an LED, so that we can time how long the program takes. We can run the program and connect to the micro:bit with minicom as before and see the primes scrolling past:
Lab 3 has a version of this program: there, prime(n) is implemented by a simple algorithm that is quite slow, particularly because it is using a naïve algorithm for division. The time to find the next prime can get quite long, particularly when large gaps begin to appear, such as the one between 3229 and 3251. (And yes, we are testing the even numbers as well as the odd ones!)
[9.4] Initialising the UART is a bit involved, but the code can be copied from manufacturer’s example programs, and amounts to making proper settings of several device registers. The two pins (defined by constants USB_TX and USB_RX ) must be configured one as an output and the other as an input, both with pullup resistors enabled. Then there is a device register that is set according to the baud rate, and another to set the format to 8N1. At the end come some assignments to start the sending and receiving processes and clear the flags that indicate the interface is ready for a character.
[9.6] Actually, this program allows a small amount of overlap between printing one prime and looking for the next one. (How?) But once the primes start to thin out, pauses start to appear between lines of output. We can show this by connecting the micro:bit up to a logic analyser and capturing a trace. I am using an inexpensive PC-based logic analyser bought on eBay: similar devices are easily found by googling «logic anaylser 24MHz 8ch». They are all based on the same Cypress microcontroller, and all the smarts are in the associated open-source software.

In the picture, the micro:bit is connected to two channels of the logic analyser, using an edge connector breakout to make the signals available on header pins.
- Channel 0 (black wire) is connected to a GPIO pin that is used to drive one of the LEDs. This shows when the LED signal is illuminated. (Detail: the column I’ve used is not one of the ones that is lit, so it is high when the LED pattern is placed on the GPIO pins, and reverts to low when the output register is reset to zero.)
- Channel 1 (brown wire) is connected to the transmit line of the UART. The transmit and receive lines between the UART and the USB interface chip are not brought out to the edge connector, but are available at certain test points on the board. In the picture, a bodge wire connects the relevant test point to a header glued to the edge of the board, on the back as we look at it. The orange wire joins the header to the brown lead of the logic analyser.
- The third connection (white wire) is ground.
The logic analyser lets us see traces of multiple signals over time: unlike an oscilloscope, it can record data from 8 channels for an almost unlimited time, but it records only a digital logic level for each channel, and not an analogue voltage. The logic analyser’s software is equipped with decoders for a variety of protocols including serial data, so we can ask it to annotate the trace with the decoded characters.
[9.7] Here is a trace of the beginning of a run of the program, on a smaller timescale than the trace we saw earlier.
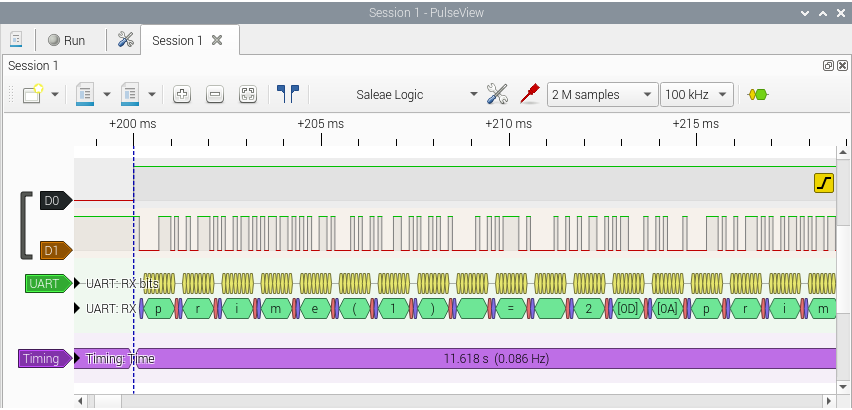
- In the picture, you can see two traces: one (Channel 0) is the long pulse that powers the LED, showing that it takes 11.618 seconds to find all 500 primes; the other (Channel 1) is the signal on the serial line, and above it a decoding of the characters that are being sent. You can see the string «prime(1) = 2» , followed by a carriage return ( [0D] ) and line feed ( [0A] ). The p that begins the next line of output «prime(2) = 3» follows immediately after the line feed without any delay.
- The scale at the top is in milliseconds, and you can see that transmitting each character takes just a bit more than 1ms.
Further along the trace, we can see delays start to appear between one line of output and the next. Two successive lines of output read
Here is the corresponding part of the logic analyser trace, zoomed about a bit to show the length of the gap between them.
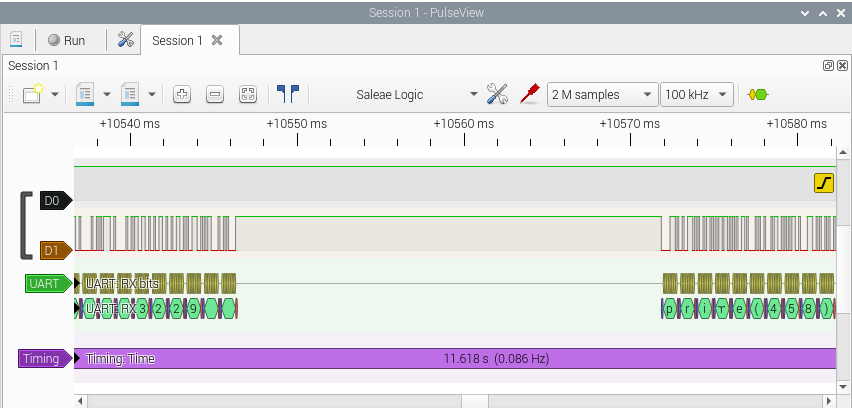
From the times at the top, you can see that this portion comes from late in the run, about 10.2s in. There is a period of 25ms or so when the serial line is idle, between the line feed that ends one line of output and the p that begins the next one. During this period, the machine is testing successive numbers to see whether they are prime, and it is spending most of its time in a loop inside the division subroutine. Once the next prime has been found, the activity changes, and the machine spends most of its time in the loop shown above, waiting for UART_TXDRDY to become true. This behaviour is silly, because instead of idly waiting for transmission of a character to finish, the micro:bit could be doing useful work towards finding the next prime. As we shall see later, we can arrange for this to happen (without having to restructure our whole program) by introducing a buffer to store pending output characters, and using interrupts to make the processor respond whenever the UART is ready for the next character, without having it sit in a loop waiting.
Serial I/O Interfaces Dominate Data Communications
Practically every electronic product made today uses one or more serial data interfaces. A serial interface is the fastest and easiest way to get data into or out of a device. With so many different types of devices populating an enormous range of applications, it should come as no surprise that literally dozens of different interfaces are available for every occasion. USB, HDMI, and RS-232 are perhaps the most common interfaces, but many others also occupy this space.
Rationale for Serial I/O
Digital data flows into or out of a circuit or device using two basic methods. The first way is via parallel data interfaces, which transfer multiple bits over parallel data paths. Parallel interfaces require one path, printed-circuit-board (PCB) trace or wire per bit plus a ground. If using balanced differential lines, two paths are required per bit. While this is the fastest way to transfer data, it’s expensive and hardware-intensive because a driver and receiver are needed for each path. And cables for long distances become large and expensive.
The primary limitation of a parallel interface is speed over distance. As data-transfer rates accelerate, the path characteristics dictate an upper limit. Parallel PCB traces or wires in a cable act as filters and transmission lines. Path inductance, capacitance, and resistance introduce attenuation and rounding, thereby limiting the data rate. Furthermore, crosstalk between lines creates mutual noise, and different path lengths introduce bit skew that may affect timing at higher speeds. On top of that, parallel buses generate a significant amount of electromagnetic interference (EMI). All of this reduces the data-transfer range.
Such limitations not only restrict range, but data rate as well. The upper limits depend on specific cases, but the upper data rate is generally in the hundreds of megabits per second over no more than about several feet. That’s why parallel transmissions are usually limited to interconnections between chips on PCBs or over short differential ribbon cables between PCBs or chassis.
Serial data interfaces, obviously the second digital-data-flow method, eliminate or at least minimize this problem. While data transfers are theoretically slower because of the bit-by-bit transfer, today’s data rates range from a few bits per second to 100 Gb/s over long distances.
Serial connections require only a single path, either unbalanced or differential. Data can travel over PCB traces, single wires, twisted pair, coax cable, or fiber-optical cable. Range can be inches to hundreds of meters, or even more. Special line drivers and receivers with equalization deal with the various path distortions. In summary, serial interfaces make it possible to go faster over longer distances with less hardware at lower cost.
One other note: Wireless interfaces are also serial—with only a single free-space path, serial transfer is the only practical method. The most popular short-range wireless interfaces are included in this article.
Categorizing Serial Interfaces
Typically, the two best ways to characterize serial interfaces is by speed and application. This article, however, categorizes interfaces as wired baseband, wired broadband, and wireless. Data provided includes speed, range, media, application, and standard designations. Applications targeted by these interfaces include automotive, consumer, industrial, and PCB interconnects and backplanes. Wireless interfaces are treated separately.
Interfaces discussed in this article are grouped by application. Maximum data rates and ranges are provided; data rate depends on range or medium length. Due to space limitations, only the most popular interfaces are listed.
• Automotive interfaces: With so much electronic equipment in cars and trucks, it was a natural evolution to connect things with buses or interfaces. Table 1 shows the most common interfaces used today.
• Consumer/video interfaces: Everyone uses these interfaces almost every day (Table 2). They’re mainly used for video connectivity or PC peripheral connections. The best example is the USB interface, which is by far the most widely used interface in the world (except for, perhaps, the RS-232 interface).
• Industrial interfaces: Factories, plants, process control, automation centers, and other manufacturing facilities all take advantage of industrial interfaces. They connect computers to one another and to a huge variety of machines, robots, sensors, actuators, and other devices such as the widely deployed programmable logic controller (PLC). Some industrial interfaces define only the basic physical layer, while others define specific networking configurations and protocols. Several of these interfaces are referred to a fieldbuses.
The old and reliable RS-232 and RS-485 interfaces still dominate in the industrial sector, but Ethernet has made massive progress in this space due to widespread network connectivity and the subsequent need for higher data rates. Table 3 summarizes the most widely used interfaces in industry, but a number of special interfaces are in play, too.
• PCB/backplane interfaces: These interfaces are designed to connect chip to chip or PCB to PCB (Table 4). The faster interfaces are used on backplanes in routers, switches, and other high-speed equipment. I 2 C and SPI interfaces dominate the chip-to-chip and PCB interconnections. PCI Express (PCIe) is the most widely used fast interface, but there’s competition from HyperTransport and RapidIO. The faster interfaces all use two or more parallel serial links to produce higher throughput.
Broadband interfaces use modulation to transmit data—serial baseband data bits modulate a carrier or carriers, which are put on a cable. This is done primarily because data can be transmitted faster over longer distances. The downside, of course, is the greater complexity and cost, since both ends of a link require modulation and demodulation. The connecting device is a modem. Table 5 runs down the most widely used broadband interfaces and their main characteristics.
Various wireless interfaces have emerged over the years for specific applications, with a range of success in terms of popularity. Some are used as a cable eliminator, while others just simplify remote connections without the expense of laying cable. Most of these interfaces are designed to cover short ranges, from a few inches up to about 100 meters. Table 6 summarizes the most prominent of this group.
All of these interfaces use the unlicensed frequency spectrum specified in the FCC rules and regulations Parts 15 and 18. Several interfaces are based on the IEEE 802.15.4 standard, including ISA100, WirelessHART, and ZigBee. Applications are across-the-board, from industrial monitoring and control, home networking, and the Internet of Things (IoT) to consumer, smart-grid and utility metering, and general networking.
Testing Serial Interfaces
Before testing any serial interface, you should be aware of the particular standard’s details. It’s best to acquire the documentation from the standards organization. Such documentation spells out the specifications and, in many cases, recommended testing procedures.
The key testing requirements are usually data speed and bit error rate (BER). BER, typically used in high-speed interface testing, is simply the percentage of bit errors per quantity of bits transmitted. BER values range from roughly 10 -5 to 10 -15 , depending on the interface.
1. The Tektronix MDO 3104 oscilloscope uses its I2C software to test and troubleshoot the interface.
Some high-speed interfaces also require eye-pattern testing and jitter measurements. Certain complex interfaces may also need protocol analysis equipment or software.
When it comes time to perform the tests, the instrument of choice is a digital oscilloscope with the appropriate software. Most scope manufacturers offer special testing software for the popular serial interfaces. It’s a superior investment, as it greatly speeds up and simplifies testing. Manufacturers such as Keysight Technologies, National Instruments, Rhode & Schwarz, Tektronix, and Teledyne Lecroy offer appropriate equipment and software. In one example, a modern oscilloscope delivers the waveforms and code for an I 2 C interface (Fig. 1). Figure 2 shows the display for an SPI interface.
2. This display from a Tektronix oscilloscope shows the waveforms and codes from an SPI interface test.
Footnote: This article is abstracted from the new book Handbook of Serial Communication Interfaces, A comprehensive compendium of serial digital input/output (I/O) standards to be published by Newnes/Elsevier in the fourth quarter of 2015.